Optimization
Efficient solutions to large-scale problems.
Much of MERL's research activity involves formulating scientific and engineering problems as optimizations, which can be solved in an efficient way. We have developed fundamental algorithms to better solve classic problems, such as quadratic programs and minimum-cost paths. Our work also involves developing theoretical bounds to understand performance limits.
Quick Links
-
Researchers
Stefano
Di Cairano
Arvind
Raghunathan
Toshiaki
Koike-Akino
Daniel N.
Nikovski
Christopher R.
Laughman
Yebin
Wang
Philip V.
Orlik
Abraham P.
Vinod
Ye
Wang
Kieran
Parsons
Scott A.
Bortoff
Avishai
Weiss
Petros T.
Boufounos
Matthew
Brand
Hassan
Mansour
Jianlin
Guo
Pu
(Perry)
Wang
Vedang M.
Deshpande
Hongbo
Sun
Hongtao
Qiao
Dehong
Liu
Bingnan
Wang
Purnanand
Elango
Chungwei
Lin
Yanting
Ma
Gordon
Wichern
Saviz
Mowlavi
William S.
Yerazunis
Nobuyuki
Yoshikawa
Jinyun
Zhang
Abraham
Goldsmith
Alexander
Schperberg
Jordan
Leung
Pedro
Miraldo
Joshua
Rapp
Anoop
Cherian
Radu
Corcodel
Anna
Deza
Kenji
Inomata
Jing
Liu
-
Awards
-
AWARD Mitsubishi Electric and MERL work recognized with IEEJ Distinguished Paper Award Date: June 1, 2025
Awarded to: Arvind Raghunathan, Daniel Nikovski
MERL Contacts: Daniel N. Nikovski; Arvind Raghunathan
Research Areas: Electric Systems, OptimizationBrief- A publication jointly authored by Mitsubishi Electric Corporation's Advanced Technology Center (ATC) and MERL researchers has been recognized with the 2025 IEEJ Distinguished Paper Award by the Institute of Electrical Engineers Japan. The paper titled "Power Band Model Based on Flow Network and Weekly Unit Commitment Problem Considering Reserve Market" published in the IEEJ Transactions on Power and Energy presents a novel Unit Commitment formulation for scheduling the generator operations. Arvind Raghunathan and Daniel Nikovksi were co-authors on this publication.
-
AWARD Mitsubishi Electric Team Wins Awards at GalFer Contest Date: June 23, 2025
Awarded to: Bingnan Wang, Tatsuya Yamamoto, Yusuke Sakamoto, Siyuan Sun, Toshiaki Koike-Akino, and Ye Wang
MERL Contacts: Toshiaki Koike-Akino; Bingnan Wang; Ye Wang
Research Areas: Machine Learning, Multi-Physical Modeling, OptimizationBrief- The MELSUR (Mitsubishi Electric SURrogate) team, consisting of a group of MERL and Mitsubishi Electric researchers, ranked first in two out of three categories in the GalFer Contest.
The GalFer (Galileo Ferraris) contest aims to compare the accuracy and efficiency of data-driven methodologies for the multi-physics simulation of traction electric machines. A total of 26 teams worldwide participated in the contest, which consists of three categories. The MELSUR team, including MERL staff Bingnan Wang, Toshiaki Koike-Akino, Ye Wang, MERL intern Siyuan Sun, Mitsubishi Electric researchers Tatsuya Yamamoto and Yusuke Sakamoto, ranked first for the category of "Novelty" and "Interpolation". The results were announced during an award ceremony at the COMPUMAG 2025 conference in Naples, Italy.
- The MELSUR (Mitsubishi Electric SURrogate) team, consisting of a group of MERL and Mitsubishi Electric researchers, ranked first in two out of three categories in the GalFer Contest.
-
AWARD MERL Researchers Win Best Workshop Poster Award at the 2023 IEEE International Conference on Robotics and Automation (ICRA) Date: June 2, 2023
Awarded to: Yuki Shirai, Devesh Jha, Arvind Raghunathan and Dennis Hong
MERL Contact: Arvind Raghunathan
Research Areas: Artificial Intelligence, Optimization, RoboticsBrief- MERL's paper titled: "Closed-Loop Tactile Controller for Tool Manipulation" Won the Best Poster Award in the workshop on "Embracing contacts : Making robots physically interact with our world". First author and MERL intern, Yuki Shirai, was presented with the award at a ceremony held at ICRA in London. MERL researchers Devesh Jha, Principal Research Scientist, and Arvind Raghunathan, Senior Principal Research Scientist and Senior Team Leader as well as Prof. Dennis Hong of University of California, Los Angeles are also coauthors.
The paper presents a technique to manipulate an object using a tool in a closed-loop fashion using vision-based tactile sensors. More information about the workshop and the various speakers can be found here https://sites.google.com/view/icra2023embracingcontacts/home.
- MERL's paper titled: "Closed-Loop Tactile Controller for Tool Manipulation" Won the Best Poster Award in the workshop on "Embracing contacts : Making robots physically interact with our world". First author and MERL intern, Yuki Shirai, was presented with the award at a ceremony held at ICRA in London. MERL researchers Devesh Jha, Principal Research Scientist, and Arvind Raghunathan, Senior Principal Research Scientist and Senior Team Leader as well as Prof. Dennis Hong of University of California, Los Angeles are also coauthors.
See All Awards for Optimization -
-
News & Events
-
NEWS MERL Presents Five Papers at IEEE Quantum Week 2026 Date: September 13, 2026 - September 18, 2026
Where: Toronto, Canada
MERL Contact: Toshiaki Koike-Akino
Research Areas: Applied Physics, Artificial Intelligence, Machine Learning, Optimization, Signal ProcessingBrief- MERL is pleased to announce that five papers have been accepted to the 2026 IEEE International Conference on Quantum Computing and Engineering (QCE), also known as IEEE Quantum Week 2026, held September 13–18, 2026, in Toronto, Canada.
The papers highlight MERL’s recent advances in quantum computing, spanning hardware-efficient quantum state preparation, quantum low-density parity-check (QLDPC) code design, graph-cover-based code construction, machine-learning-assisted code search, and reinforcement-learning-guided quantum error correction. Together, these works address important challenges toward more efficient and reliable quantum computing systems.
The five papers are:
- “Near-Lower-Bound Approximate Quantum State Preparation with Hardware-Efficient Circuits” — Toshiaki Koike-Akino (TR2026-131)
- “Reinforcement-Learning-Guided Multi-Branch Decoding of Quantum LDPC Codes” — Vahid Nourozi, Toshiaki Koike-Akino, and David Mitchell (TR2026-130)
- “Q-Learning Base Search Voltage-Labeled Covers for Weight-Six Bivariate-Bicycle Quantum LDPC Codes” — Vahid Nourozi, David Mitchell, and Toshiaki Koike-Akino (TR2026-132)
- “Collision-Voltage Design of Directional Covers for Bivariate Bicycle Quantum LDPC Codes” — Vahid Nourozi, David Mitchell, and Toshiaki Koike-Akino (TR2026-133)
- “Base-Preserving APM/Voltage Lifts of Bivariate Bicycle Quantum LDPC Codes” — Vahid Nourozi, David Mitchell, and Toshiaki Koike-Akino (TR2026-129)
- MERL is pleased to announce that five papers have been accepted to the 2026 IEEE International Conference on Quantum Computing and Engineering (QCE), also known as IEEE Quantum Week 2026, held September 13–18, 2026, in Toronto, Canada.
-
NEWS MERL collaborator Yuri Shimane receives IFAC Young Author Applications Paper Prize Date: August 28, 2026
MERL Contacts: Stefano Di Cairano; Avishai Weiss
Research Areas: Control, Dynamical Systems, OptimizationBrief- MERL collaborator and former intern Prof. Yuri Shimane received the IFAC Young Author Applications Paper Prize at the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea for a paper co-authored with MERL researchers.
The award recognized Prof. Shimane paper, “Scenario-Based Model Predictive Control for Station Keeping on Near-Rectilinear Halo Orbit,” co-authored with Masafumi Isaji and MERL researchers Avishai Weiss and Stefano Di Cairano.
MERL congratulates Yuri and his co-authors on this recognition.
- MERL collaborator and former intern Prof. Yuri Shimane received the IFAC Young Author Applications Paper Prize at the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea for a paper co-authored with MERL researchers.
See All News & Events for Optimization -
-
Research Highlights
-
Internships
-
CI0213: Internship - Efficient Foundation Models for Edge Intelligence
-
CA0153: Internship - High-Fidelity Visualization and Simulation for Space Applications
-
CI0314: Internship - Embodied AI & Humanoid Robotics
See All Internships for Optimization -
-
Openings
-
SA0297: Postdoctoral Research Fellow - AI for Science
-
CI0177: Postdoctoral Research Fellow - Agentic AI
-
MS0268: Research Scientist - Plasma Modeling and Control
See All Openings at MERL -
-
Recent Publications
- , "Fast Adaptive Planning for Autonomous Tractor-Trailer Systems via Iterative LQR Steering", IEEE Conference on Automation and Science Engineering, August 2026.BibTeX TR2026-118 PDF
- @inproceedings{Zhou2026aug,
- author = {Zhou, Tianyu and Wang, Yebin and Umat, Akhil and Tiwari, Astha and {Di Cairano}, Stefano},
- title = {{Fast Adaptive Planning for Autonomous Tractor-Trailer Systems via Iterative LQR Steering}},
- booktitle = {IEEE Conference on Automation and Science Engineering},
- year = 2026,
- month = aug,
- url = {https://www.merl.com/publications/TR2026-118}
- }
- , "Nonlinear Model Predictive Control for High-Thrust Geostationary Station Keeping using Averaged Dynamics", World Congress of the International Federation of Automatic Control (IFAC), August 2026.BibTeX TR2026-117 PDF
- @inproceedings{Pavlasek2026aug,
- author = {Pavlasek, Natalia and Acikmese, Behcet and {Di Cairano}, Stefano and Weiss, Avishai},
- title = {{Nonlinear Model Predictive Control for High-Thrust Geostationary Station Keeping using Averaged Dynamics}},
- booktitle = {World Congress of the International Federation of Automatic Control (IFAC)},
- year = 2026,
- month = aug,
- url = {https://www.merl.com/publications/TR2026-117}
- }
- , "Coordinated Energy-Aware Job Scheduling and Flexibility Provisioning in Distributed Data Centers", IEEE PES General Meeting, July 2026.BibTeX TR2026-113 PDF
- @inproceedings{Kar2026jul,
- author = {Kar, Aditya Shankar and Sun, Hongbo and Raghunathan, Arvind and Guo, Jianlin},
- title = {{Coordinated Energy-Aware Job Scheduling and Flexibility Provisioning in Distributed Data Centers}},
- booktitle = {IEEE PES General Meeting},
- year = 2026,
- month = jul,
- url = {https://www.merl.com/publications/TR2026-113}
- }
- , "Scalable DAE-Constrained PINODE Framework for Vapor-Compression HVAC Systems", International Refrigeration and Air Conditioning Conference at Purdue, July 2026.BibTeX TR2026-111 PDF
- @inproceedings{Zhai2026jul,
- author = {Zhai, Hanfeng and Qiao, Hongtao and Mansour, Hassan and Laughman, Christopher R.},
- title = {{Scalable DAE-Constrained PINODE Framework for Vapor-Compression HVAC Systems}},
- booktitle = {International Refrigeration and Air Conditioning Conference at Purdue},
- year = 2026,
- month = jul,
- url = {https://www.merl.com/publications/TR2026-111}
- }
- , "On State Selection for Vapor Compression Cycle Models with Zeotropic Refrigerant Mixtures", Purdue Air-Conditioning and Refrigeration Conference, July 2026.BibTeX TR2026-109 PDF
- @inproceedings{Laughman2026jul,
- author = {{Laughman, Christopher R. and Qiao, Hongtao and Bortoff, Scott A. and Deshpande, Vedang M.}},
- title = {{On State Selection for Vapor Compression Cycle Models with Zeotropic Refrigerant Mixtures}},
- booktitle = {Purdue Air-Conditioning and Refrigeration Conference},
- year = 2026,
- month = jul,
- url = {https://www.merl.com/publications/TR2026-109}
- }
- , "MOBIUS: A Multi-Modal Bipedal Robot that can Walk, Crawl, Climb, and Roll", Robotics Science and Systems, July 2026.BibTeX TR2026-110 PDF Video
- @inproceedings{Schperberg2026jul,
- author = {Schperberg, Alexander and Tanaka, Yusuke and {Di Cairano}, Stefano and Hong, Dennis},
- title = {{MOBIUS: A Multi-Modal Bipedal Robot that can Walk, Crawl, Climb, and Roll}},
- booktitle = {Robotics Science and Systems},
- year = 2026,
- month = jul,
- url = {https://www.merl.com/publications/TR2026-110}
- }
- , "Coordinated aerial inspection of infrastructure with heterogeneous drones", World Congress of the International Federation of Automatic Control (IFAC), July 2026.BibTeX TR2026-101 PDF Software
- @inproceedings{Folorunsho2026jul,
- author = {Folorunsho, Samuel and Hayner, Christopher and {Di Cairano}, Stefano and Vinod, Abraham P.},
- title = {{Coordinated aerial inspection of infrastructure with heterogeneous drones}},
- booktitle = {World Congress of the International Federation of Automatic Control (IFAC)},
- year = 2026,
- month = jul,
- url = {https://www.merl.com/publications/TR2026-101}
- }
- , "Closed-Loop Co-Design of Motors, Motions, and Feedback Control for Robotic Manipulators", Journal of Artificial Intelligence for Automation, DOI: 10.53941/jaia.2026.100008, Vol. 1, No. 2, June 2026.BibTeX TR2026-088 PDF
- @article{Lin2026jun2,
- author = {Lin, Jue-Te and Lu, Zehui and Wang, Yebin},
- title = {{Closed-Loop Co-Design of Motors, Motions, and Feedback Control for Robotic Manipulators}},
- journal = {Journal of Artificial Intelligence for Automation},
- year = 2026,
- volume = 1,
- number = 2,
- month = jun,
- doi = {10.53941/jaia.2026.100008},
- url = {https://www.merl.com/publications/TR2026-088}
- }
- , "Fast Adaptive Planning for Autonomous Tractor-Trailer Systems via Iterative LQR Steering", IEEE Conference on Automation and Science Engineering, August 2026.
-
Videos
-
Software & Data Downloads
-
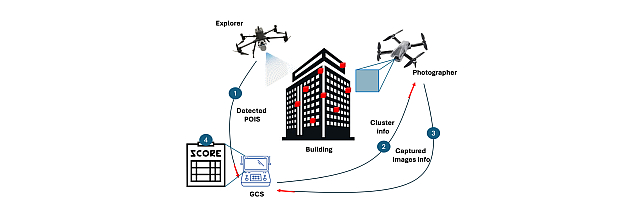
ROS 2 Cooperative Aerial Robots Inspection Challenge -
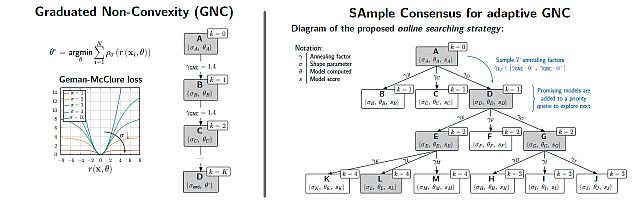
SAmple Consensus for Adaptive Graduated Non-Convexity -
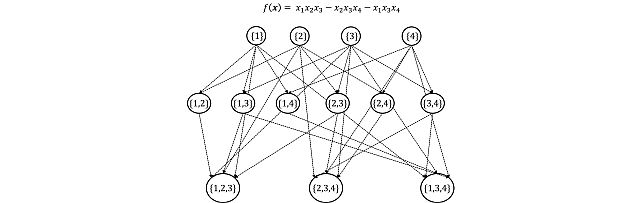
Optimal Recursive McCormick Linearization of MultiLinear Programs -
Convex sets in Python -
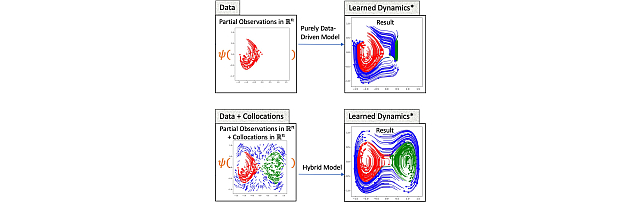
Physics-Informed Neural ODE -
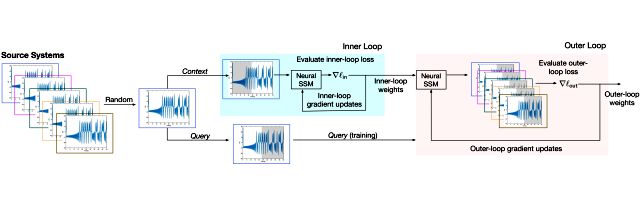
Meta-Learning State Space Models -
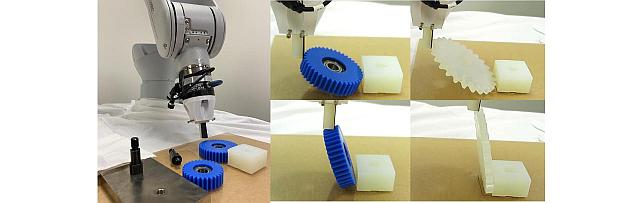
Python-based Robotic Control & Optimization Package -
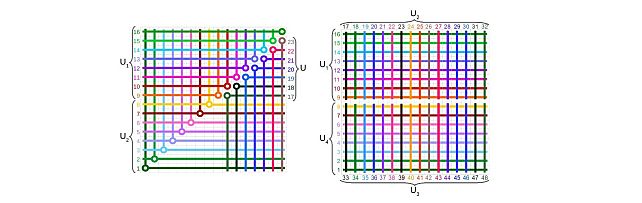
Template Embeddings for Adiabatic Quantum Computation -
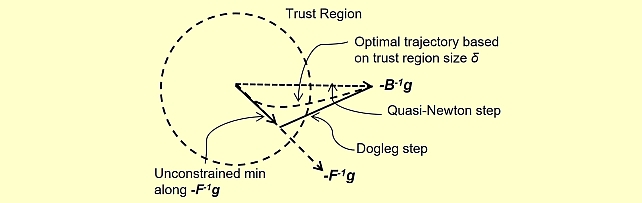
Quasi-Newton Trust Region Policy Optimization -
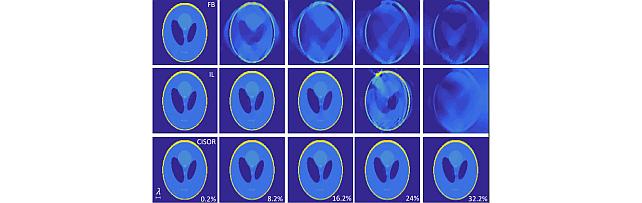
Convergent Inverse Scattering using Optimization and Regularization
-