Ye Wang
- Phone: 617-621-7521
- Email:
-
Position:
Research / Technical Staff
Senior Principal Research Scientist -
Education:
Ph.D., Boston University, 2011 -
Research Areas:
External Links:
Ye's Quick Links
-
Biography
Ye was a member of the Information Systems and Sciences Laboratory at Boston University, where he studied information-theoretically secure multiparty computation. His current research interests include information security, biometric authentication, and data privacy.
-
Recent News & Events
-
NEWS MERL contributes to IROS 2026 Date: September 27, 2026 - October 1, 2026
Where: The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
MERL Contacts: Siddarth Jain; Toshiaki Koike-Akino; Jing Liu; Daniel N. Nikovski; Arvind Raghunathan; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
Main Conference Paper
- ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation, Yunfu Deng and Daniel N. Nikovski (TR2026-141)
The work introduces a geometric representation for articulated-object manipulation, enabling robots to infer compact representations of previously unknown articulated mechanisms for downstream learning and control.
Workshop Papers
- Deliberate Practice: Learning Robot Skills under a Budget Shivam Vats, Sudarshan Harithas, Mete Akbulut, Arvind Raghunathan, and George Konidaris (TR2026-147)
- ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies, Haodi Hu, Chung-Ta Huang, Jing Liu, Ye Wang, Kei Suzuki, Matthew Brand, and Toshiaki Koike-Akino (TR2026-148)
- Test-Time Attention: Can Robots Better Follow Commands? Jing Liu, Ye Wang, Kei Suzuki, and Toshiaki Koike-Akino (TR2026-142)
- Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation, Chak Lam Shek, Ye Wang, Jing Liu, Kei Suzuki, Pratap Tokekar, and Toshiaki Koike-Akino (TR2026-149)
- DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments, Harsh Singh, Kei Suzuki, Ye Wang, Jing Liu, Paola Cascante-Bonilla, and Toshiaki Koike-Akino (TR2026-146)
Together, these works address a range of challenges in modern robotics, including articulated-object manipulation, efficient robot skill learning, vision-language-action policies, test-time adaptation, autonomous factory operation, and dynamic manipulation. The paper on ReCoVLA was nominated as a spotlight talk.
Robotics Community Contributions
MERL Principal Research Scientist Dr. Siddarth Jain participated in the IEEE Robotics and Automation Letters (RA-L) editorial board meeting at IROS. Dr. Jain serves as an Associate Editor of RA-L, contributing to the peer-review and editorial activities of the robotics research community.
Former MERL scientist Dr. Diego Romeres was also among the organizers of the 1st International Workshop on Industrial Applications of Robot Learning (IARL 2026). The workshop brought together researchers from academia and industry to discuss how advances in robot learning can be translated into reliable and scalable real-world industrial robotic systems.
Humanoid IKEA Assembly Challenge
MERL also participated in the IROS 2026 Humanoid IKEA Assembly Challenge with Team MEL-Craft. The team achieved first place in the competition, demonstrating autonomous humanoid manipulation capabilities for a challenging furniture-assembly task. The MEL-Craft team included MERL researchers Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Haodi Hu, Harsh Singh, Chak Lam Shek, and Maxwell Asselmeier. The competition achievement is highlighted separately in MERL's related award announcement.
About IROS
The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) is a major international robotics conference bringing together researchers, engineers, and industry practitioners working across intelligent robots and systems. IROS 2026 took place in Pittsburgh from September 27 to October 1, 2026.
- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
-
NEWS MERL Presents 4 Main Conference Papers and 6 Workshop Papers at ICML 2026 Date: July 6, 2026 - July 11, 2026
Where: COEX, Seoul, South Korea
MERL Contacts: Moitreya Chatterjee; Anoop Cherian; Stefano Di Cairano; Toshiaki Koike-Akino; Christopher R. Laughman; Jing Liu; Suhas Lohit; Kuan-Chuan Peng; Alexander Schperberg; Ye Wang; Gordon Wichern
Research Areas: Artificial Intelligence, Computer Vision, Machine Learning, Signal ProcessingBrief- MERL researchers are proud to present 4 main conference papers and 6 workshop papers at ICML 2026. ICML, taking place from July 6-11 in Seoul, South Korea, is a premier international conference in machine learning.
Main Conference Papers with MERL Authors:
1. Understanding Dynamic Compute Allocation in Recurrent Transformers by Ibraheem Muhammad Moosa, Suhas Lohit, Ye Wang, Moitreya Chatterjee, and Wenpeng Yin.
2. LLawCo: Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior by Qinhong Zhou, Chuang Gan, and Anoop Cherian.
3. Memory-Distilled Selection for Noise-Robust Anomaly Detection by Sirojbek Safarov, Jaewoo Park, Yoon G. Jung, Kuan-Chuan Peng, Wonchul Kim, Seongdeok Bang, and Octavia Camps.
4. Partial Ring Scan: Revisiting Scan Order in Vision State Space Models by Yi-Kuan Hsieh, Kuan-Chuan Peng, Xin Li, Ming-Ching Chang, Yu-Chee Tseng, and Jun-Wei Hsieh.
Workshop Papers with MERL Authors:
1. WISE: Weighted Iterative Society-of-Experts for Multimodal Multi-Agent Debate with Probabilistic Consensus by Anoop Cherian, Suhas Lohit, and Kuan-Chuan Peng. (Workshop on Scalable Learning and Optimization for Efficient Multimodal AI Agents (SCALE))
2. MIRROR: Multisensory Implicit Rejection-sampled RObotic policy by Amisha Bhaskar, Pratap Tokekar, Stefano Di Cairano, and Alexander Schperberg. (Workshop on Structured Probabilistic Inference & Generative Modeling)
3. Reinforced Neural Processes: Memory-Efficient Time-Series Forecasting with a World-Feedback-Trained Memory Policy by Nibraas Khan, Gordon Wichern, and Christopher R. Laughman. (Workshop on Reinforcement Learning from World Feedback (RLxF))
4. Connecting Low-Rank Adapters and Policy Stability in GRPO Fine-Tuning by Antonin Rottman, Francesco Tonin, Yongtao Wu, Toshiaki Koike-Akino, and Volkan Cevher. (Workshop on Connecting Low-rank Representations in AI (CoLorAI))
5. EinSort: Sorting is All We Need for Tensorizing LLM by Toshiaki Koike-Akino, Jing Liu, and Ye Wang. (Workshop on Connecting Low-rank Representations in AI (CoLorAI))
6. Temper and Tilt Lead to SLOP: Reward Hacking Mitigation with Inference-Time Alignment by Ye Wang, and Jing Liu, and Toshiaki Koike-Akino. (Workshop on Agents in the Wild: Safety, Security, and Beyond)
- MERL researchers are proud to present 4 main conference papers and 6 workshop papers at ICML 2026. ICML, taking place from July 6-11 in Seoul, South Korea, is a premier international conference in machine learning.
See All News & Events for Ye -
-
Awards
-
AWARD MERL Team Wins IROS 2026 Humanoid IKEA Assembly Challenge Date: October 1, 2026
Awarded to: Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, Ye Wang, Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu
MERL Contacts: Toshiaki Koike-Akino; Jing Liu; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
The challenge asked teams to develop autonomous robot policies for a Unitree G1 humanoid robot to assemble an IKEA UTTER table from its component parts. The robot had to perform the task autonomously at the competition venue, requiring capabilities including perception, bimanual manipulation, spatial reasoning, planning, and control. Human intervention was penalized, and teams were evaluated based on assembly progress and completion time.
MERL competed as MEL-Craft and achieved first place in the competition. The result demonstrates progress toward reliable humanoid robots capable of performing complex, contact-rich manipulation tasks in real-world environments, an important direction for physical AI and general-purpose robotic systems.
The MERL team members were Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu.
The Humanoid IKEA Assembly Challenge was held as part of IROS 2026, the IEEE/RSJ International Conference on Intelligent Robots and Systems.
- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
-
AWARD Mitsubishi Electric Team Wins Awards at GalFer Contest Date: June 23, 2025
Awarded to: Bingnan Wang, Tatsuya Yamamoto, Yusuke Sakamoto, Siyuan Sun, Toshiaki Koike-Akino, and Ye Wang
MERL Contacts: Toshiaki Koike-Akino; Bingnan Wang; Ye Wang
Research Areas: Machine Learning, Multi-Physical Modeling, OptimizationBrief- The MELSUR (Mitsubishi Electric SURrogate) team, consisting of a group of MERL and Mitsubishi Electric researchers, ranked first in two out of three categories in the GalFer Contest.
The GalFer (Galileo Ferraris) contest aims to compare the accuracy and efficiency of data-driven methodologies for the multi-physics simulation of traction electric machines. A total of 26 teams worldwide participated in the contest, which consists of three categories. The MELSUR team, including MERL staff Bingnan Wang, Toshiaki Koike-Akino, Ye Wang, MERL intern Siyuan Sun, Mitsubishi Electric researchers Tatsuya Yamamoto and Yusuke Sakamoto, ranked first for the category of "Novelty" and "Interpolation". The results were announced during an award ceremony at the COMPUMAG 2025 conference in Naples, Italy.
- The MELSUR (Mitsubishi Electric SURrogate) team, consisting of a group of MERL and Mitsubishi Electric researchers, ranked first in two out of three categories in the GalFer Contest.
-
AWARD MERL Wins Awards at NeurIPS LLM Privacy Challenge Date: December 15, 2024
Awarded to: Jing Liu, Ye Wang, Toshiaki Koike-Akino, Tsunato Nakai, Kento Oonishi, Takuya Higashi
MERL Contacts: Toshiaki Koike-Akino; Jing Liu; Ye Wang
Research Areas: Artificial Intelligence, Machine Learning, Information SecurityBrief- The Mitsubishi Electric Privacy Enhancing Technologies (MEL-PETs) team, consisting of a collaboration of MERL and Mitsubishi Electric researchers, won awards at the NeurIPS 2024 Large Language Model (LLM) Privacy Challenge. In the Blue Team track of the challenge, we won the 3rd Place Award, and in the Red Team track, we won the Special Award for Practical Attack.
-
AWARD MERL’s Paper on Wi-Fi Sensing Earns Top 3% Paper Recognition at ICASSP 2023, Selected as a Best Student Paper Award Finalist Date: June 9, 2023
Awarded to: Cristian J. Vaca-Rubio, Pu Wang, Toshiaki Koike-Akino, Ye Wang, Petros Boufounos and Petar Popovski
MERL Contacts: Petros T. Boufounos; Toshiaki Koike-Akino; Pu (Perry) Wang; Ye Wang
Research Areas: Artificial Intelligence, Communications, Computational Sensing, Dynamical Systems, Machine Learning, Signal ProcessingBrief- A MERL Paper on Wi-Fi sensing was recognized as a Top 3% Paper among all 2709 accepted papers at the 2023 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP 2023). Co-authored by Cristian Vaca-Rubio and Petar Popovski from Aalborg University, Denmark, and MERL researchers Pu Wang, Toshiaki Koike-Akino, Ye Wang, and Petros Boufounos, the paper "MmWave Wi-Fi Trajectory Estimation with Continous-Time Neural Dynamic Learning" was also a Best Student Paper Award finalist.
Performed during Cristian’s stay at MERL first as a visiting Marie Skłodowska-Curie Fellow and then as a full-time intern in 2022, this work capitalizes on standards-compliant Wi-Fi signals to perform indoor localization and sensing. The paper uses a neural dynamic learning framework to address technical issues such as low sampling rate and irregular sampling intervals.
ICASSP, a flagship conference of the IEEE Signal Processing Society (SPS), was hosted on the Greek island of Rhodes from June 04 to June 10, 2023. ICASSP 2023 marked the largest ICASSP in history, boasting over 4000 participants and 6128 submitted papers, out of which 2709 were accepted.
- A MERL Paper on Wi-Fi sensing was recognized as a Top 3% Paper among all 2709 accepted papers at the 2023 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP 2023). Co-authored by Cristian Vaca-Rubio and Petar Popovski from Aalborg University, Denmark, and MERL researchers Pu Wang, Toshiaki Koike-Akino, Ye Wang, and Petros Boufounos, the paper "MmWave Wi-Fi Trajectory Estimation with Continous-Time Neural Dynamic Learning" was also a Best Student Paper Award finalist.
-
AWARD MERL Ranked 1st Place in Cross-Subject Transfer Learning Task and 4th Place Overall at the NeurIPS2021 BEETL Competition for EEG Transfer Learning. Date: November 11, 2021
Awarded to: Niklas Smedemark-Margulies, Toshiaki Koike-Akino, Ye Wang, Deniz Erdogmus
MERL Contacts: Toshiaki Koike-Akino; Ye Wang
Research Areas: Artificial Intelligence, Signal Processing, Human-Computer InteractionBrief- The MERL Signal Processing group achieved first place in the cross-subject transfer learning task and fourth place overall in the NeurIPS 2021 BEETL AI Challenge for EEG Transfer Learning. The team included Niklas Smedemark-Margulies (intern from Northeastern University), Toshiaki Koike-Akino, Ye Wang, and Prof. Deniz Erdogmus (Northeastern University). The challenge addresses two types of transfer learning tasks for EEG Biosignals: a homogeneous transfer learning task for cross-subject domain adaptation; and a heterogeneous transfer learning task for cross-data domain adaptation. There were 110+ registered teams in this competition, MERL ranked 1st in the homogeneous transfer learning task, 7th place in the heterogeneous transfer learning task, and 4th place for the combined overall score. For the homogeneous transfer learning task, MERL developed a new pre-shot learning framework based on feature disentanglement techniques for robustness against inter-subject variation to enable calibration-free brain-computer interfaces (BCI). MERL is invited to present our pre-shot learning technique at the NeurIPS 2021 workshop.
-
-
Research Highlights
-
ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies -
BodyVLA: Embedding Morphology into Transformers for Cross-Robot Policy Learning -
Quantum AI Technology -
TI2V-Zero: Zero-Shot Image Conditioning for Text-to-Video Diffusion Models -
Private, Secure, and Reliable Artificial Intelligence -
Steered Diffusion -
Sustainable AI -
Robust Machine Learning -
Biosignal Processing for Human-Machine Interaction
-
-
MERL Publications
- , "ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.BibTeX TR2026-148 PDF
- @inproceedings{Hu2026sep,
- author = {Hu, Haodi and Huang, Chung-Ta and Liu, Jing and Wang, Ye and Suzuki, Kei and Brand, Matthew and Koike-Akino, Toshiaki},
- title = {{ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-148}
- }
- , "DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.BibTeX TR2026-146 PDF
- @inproceedings{Singh2026sep,
- author = {Singh, Harsh and Suzuki, Kei and Wang, Ye and Liu, Jing and Cascante-Bonilla, Paola and Koike-Akino, Toshiaki},
- title = {{DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-146}
- }
- , "Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.BibTeX TR2026-149 PDF
- @inproceedings{Shek2026sep,
- author = {Shek, Chak.Lam and Wang, Ye and Liu, Jing and Suzuki, Kei and Tokekar, Pratap and Koike-Akino, Toshiaki},
- title = {{Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-149}
- }
- , "Test-Time Attention: Can Robots Better Follow Commands?", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) IARL Workshop, September 2026.BibTeX TR2026-142 PDF
- @inproceedings{Liu2026sep,
- author = {Liu, Jing and Wang, Ye and Suzuki, Kei and Koike-Akino, Toshiaki},
- title = {{Test-Time Attention: Can Robots Better Follow Commands?}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) IARL Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-142}
- }
- , "Vibe Patenting: Evaluating LLM Judges for Professional Patent-Drafting Agents", arXiv, September 2026.BibTeX arXiv
- @article{Koike-Akino2026sep,
- author = {{Koike-Akino, Toshiaki and Blaykhman, Vlad and Wang, Ye and Liu, Jing and Vinokur, Gennadiy V.}},
- title = {{Vibe Patenting: Evaluating LLM Judges for Professional Patent-Drafting Agents}},
- journal = {arXiv},
- year = 2026,
- month = sep,
- url = {https://arxiv.org/abs/2609.13422}
- }
- , "ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.
-
Software & Data Downloads
-
Understanding Dynamic Compute Allocation in Recurrent Transformers -
Directional Embedding Smoothing for Robust Vision Language Models -
Stabilizing Subject Transfer in EEG Classification with Divergence Estimation -
MEL-PETs Defense for LLM Privacy Challenge -
MEL-PETs Joint-Context Attack for LLM Privacy Challenge -
Zero-Shot Image Conditioning for Text-to-Video Diffusion Models -
Steered Diffusion -
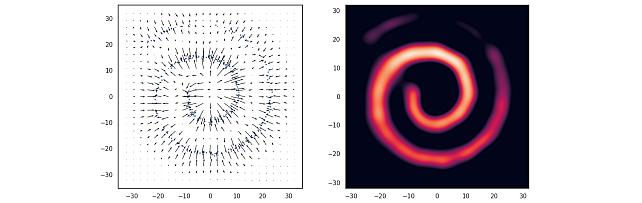
Nonparametric Score Estimators -
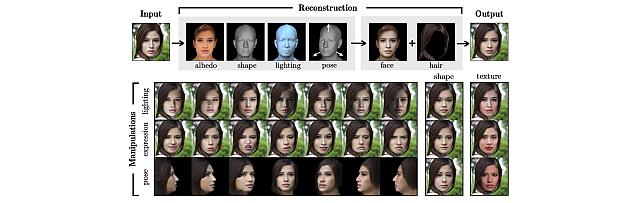
3D MOrphable STyleGAN -
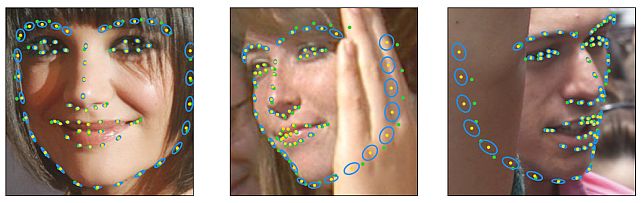
Landmarks’ Location, Uncertainty, and Visibility Likelihood
-
-
Videos
-
MERL Issued Patents
-
Title: "Stochastic Control Subject to Generative AI-Based Disturbance"
Inventors: Chakrabarty, Ankush; Wang, Ye; Laughman, Christopher; Koike-Akino, Toshiaki; Wichern, Gordon P; Salatiello, Alessandro; Sorourifar, Farshud; Paulson, Joel
Patent No.: 12,769,266
Issue Date: Oct 20, 2026 -
Title: "System and Method for Generating Two-Dimensional (2D) Image of an Object in a Scene"
Inventors: Marks, Tim; Dey, Rahul; Egger, Bernhard; Wang, Ye
Patent No.: 12,675,919
Issue Date: Jul 7, 2026 -
Title: "Method and System for Training a Neural Network for Generating Universal Adversarial Perturbations"
Inventors: Wang, Ye; Aeron, Shuchin; Rakin, Adnan; Koike-Akino, Toshiaki; Moulin, Pierre; Parsons, Kieran
Patent No.: 12,645,933
Issue Date: Jun 2, 2026 -
Title: "Integrated Sensing and Communications Empowered by Networked Hybrid Quantum-Classical Machine Learning"
Inventors: Koike-Akino, Toshiaki; Wang, Ye; Wang, Pu
Patent No.: 12,639,612
Issue Date: May 26, 2026 -
Title: "Reconfigurable wavelength selective splitter"
Inventors: Kojima, Keisuke; Jung, Minwoo; Koike-Akino, Toshiaki; Wang, Ye; Brand, Matthew E.
Patent No.: 12,639,552
Issue Date: May 26, 2026 -
Title: "Learning-Based Nonlinear Compensation with Physics-Informed Neural Network for Data Access"
Inventors: Koike-Akino, Toshiaki; Dzieciol, Hubert; Parsons, Kieran; Wang, Ye
Patent No.: 12,614,059
Issue Date: Apr 28, 2026 -
Title: "Phase Identification of Power Distribution Systems"
Inventors: Sun, Hongbo; Ye, Zong-Jhen; Guo, Jianlin; Wang, Ye
Patent No.: 12,607,662
Issue Date: Apr 21, 2026 -
Title: "System and Method for Training a Regression Neural Network for Localization of a Device in an Environment"
Inventors: Wang, Pu; Xia, Haifeng; Koike-Akino, Toshiaki; Wang, Ye; Orlik, Philip V.
Patent No.: 12,572,815
Issue Date: Mar 10, 2026 -
Title: "Generative Model for Inverse Design of Materials, Devices, and Structures"
Inventors: Kojima, Keisuke; Koike-Akino, Toshiaki; Tang, Yingheng; Wang, Ye
Patent No.: 12,260,339
Issue Date: Mar 25, 2025 -
Title: "Automated Construction of Neural Network Architecture with Bayesian Graph Exploration"
Inventors: Koike-Akino, Toshiaki; Wang, Ye; Demir, Andac; Erdogmus, Deniz
Patent No.: 12,061,985
Issue Date: Aug 13, 2024 -
Title: "Anomaly Detection and Diagnosis in Factory Automation System using Pre-Processed Time-Delay Neural Network with Loss Function Adaptation"
Inventors: Guo, Jianlin; Liu, Bryan; Koike-Akino, Toshiaki; Wang, Ye; Kim, Kyeong-Jin; Parsons, Kieran; Orlik, Philip V.
Patent No.: 12,007,760
Issue Date: Jun 11, 2024 -
Title: "Multi-Band Wi-Fi Fusion for WLAN Sensing"
Inventors: Wang, Pu; Yu, Jianyuan; Koike-Akino, Toshiaki; Wang, Ye; Orlik, Philip V.
Patent No.: 11,902,811
Issue Date: Feb 13, 2024 -
Title: "Apparatus and Method for Anomaly Detection"
Inventors: Wang, Ye; Kim, Kyeong-Jin; Wang, Xiao
Patent No.: 11,843,623
Issue Date: Dec 12, 2023 -
Title: "System and Method for Manipulating Two-Dimensional (2D) Images of Three-Dimensional (3D) Objects"
Inventors: Marks, Tim; Medin, Safa; Cherian, Anoop; Wang, Ye
Patent No.: 11,663,798
Issue Date: May 30, 2023 -
Title: "Non-Uniform Regularization in Artificial Neural Networks for Adaptable Scaling"
Inventors: Wang, Ye; Koike-Akino, Toshiaki
Patent No.: 11,651,225
Issue Date: May 16, 2023 -
Title: "Protograph Quasi-Cyclic Polar Codes and Related Low-Density Generator Matrix Family"
Inventors: Koike-Akino, Toshiaki; Wang, Ye
Patent No.: 11,463,114
Issue Date: Oct 4, 2022 -
Title: "Battery Diagnostic System for Estimating Remaining useful Life (RUL) of a Battery"
Inventors: Gorrachategui, Ivan Sanz; Pajovic, Milutin; Wang, Ye
Patent No.: 11,346,891
Issue Date: May 31, 2022 -
Title: "Generative Model for Inverse Design of Materials, Devices, and Structures"
Inventors: Kojima, Keisuke; Tang, Yingheng; Koike-Akino, Toshiaki; Wang, Ye
Patent No.: 11,251,896
Issue Date: Feb 15, 2022 -
Title: "DATA-DRIVEN PRIVACY-PRESERVING COMMUNICATION"
Inventors: Wang, Ye; Ishwar, Prakash; Tripathy, Ardhendu S
Patent No.: 11,132,453
Issue Date: Sep 28, 2021 -
Title: "Irregular Polar Code Encoding"
Inventors: Koike-Akino, Toshiaki; Wang, Ye; Draper, Stark C.
Patent No.: 10,862,621
Issue Date: Dec 8, 2020 -
Title: "Method and Systems using Privacy-Preserving Analytics for Aggregate Data"
Inventors: Wang, Ye; Raval, Nisarg Jagdishbhai; Ishwar, Prakash
Patent No.: 10,452,865
Issue Date: Oct 22, 2019 -
Title: "Irregular Polar Code Encoding"
Inventors: Koike-Akino, Toshiaki; Wang, Ye; Draper, Stark C.
Patent No.: 10,313,056
Issue Date: Jun 4, 2019 -
Title: "Soft-Output Decoding of Codewords Encoded with Polar Code"
Inventors: Wang, Ye; Koike-Akino, Toshiaki; Draper, Stark C.
Patent No.: 10,312,946
Issue Date: Jun 4, 2019 -
Title: "Method and Systems using Privacy-Preserving Analytics for Aggregate Data"
Inventors: Wang, Ye; Hattori, Mitsuhiro; Shimizu, Rina; Hirano, Takato; Matsuda, Nori
Patent No.: 10,216,959
Issue Date: Feb 26, 2019 -
Title: "Privacy Preserving Statistical Analysis on Distributed Databases"
Inventors: Wang, Ye; Lin, Bing-Rong; Rane, Shantanu D.
Patent No.: 10,146,958
Issue Date: Dec 4, 2018 -
Title: "Method and System for Determining Hidden States of a Machine using Privacy-Preserving Distributed Data Analytics and a Semi-trusted Server and a Third-Party"
Inventors: Wang, Ye
Patent No.: 9,471,810
Issue Date: Oct 18, 2016 -
Title: "Method for Determining Hidden States of Systems using Privacy-Preserving Distributed Data Analytics"
Inventors: Wang, Ye; Xie, Qian; Rane, Shantanu D.
Patent No.: 9,246,978
Issue Date: Jan 26, 2016 -
Title: "Privacy Preserving Statistical Analysis for Distributed Databases"
Inventors: Wang, Ye; Lin, Bing-Rong; Rane, Shantanu D.
Patent No.: 8,893,292
Issue Date: Nov 18, 2014 -
Title: "Secure Multi-Party Computation of Normalized Sum-Type Functions"
Inventors: Rane, Shantanu D.; Sun, Wei; Wang, Ye
Patent No.: 8,473,537
Issue Date: Jun 25, 2013
-
Title: "Stochastic Control Subject to Generative AI-Based Disturbance"