Machine Learning
Data-driven approaches to design intelligent algorithms.
MERL has a long history of research activity in machine learning, including the development of various boosting algorithms and contributing to the theory and practice of highly scalable collaborative filtering. Our recent work has focused on deep learning and reinforcement learning, with application to a wide range of applications including automotive, robotics, factory automation, transportation, as well as building and home systems.
Quick Links
-
Researchers
Toshiaki
Koike-Akino
Ye
Wang
Jonathan
Le Roux
Gordon
Wichern
Ankush
Chakrabarty
Anoop
Cherian
Pu
(Perry)
Wang
Tim K.
Marks
Michael J.
Jones
Jing
Liu
Christopher R.
Laughman
Stefano
Di Cairano
Kieran
Parsons
Philip V.
Orlik
Yoshiki
Masuyama
Suhas
Lohit
Daniel N.
Nikovski
Chiori
Hori
Bingnan
Wang
Yebin
Wang
Matthew
Brand
Hassan
Mansour
Kuan-Chuan
Peng
Petros T.
Boufounos
Moitreya
Chatterjee
Abraham P.
Vinod
Christoph
Boeddeker
Pedro
Miraldo
Siddarth
Jain
Arvind
Raghunathan
Vedang M.
Deshpande
Jianlin
Guo
Saviz
Mowlavi
Julius
Richter
Hongtao
Qiao
Radu
Corcodel
Scott A.
Bortoff
Chungwei
Lin
Dehong
Liu
William S.
Yerazunis
Hongbo
Sun
Kei
Suzuki
Joshua
Rapp
Alexander
Schperberg
Nobuyuki
Yoshikawa
Wael H.
Ali
Abraham
Goldsmith
Yanting
Ma
Lalit
Manam
Zhaolin
Ren
Anthony
Vetro
Jinyun
Zhang
Purnanand
Elango
Avishai
Weiss
Kenji
Inomata
-
Awards
-
AWARD MERL Team Wins IROS 2026 Humanoid IKEA Assembly Challenge Date: October 1, 2026
Awarded to: Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, Ye Wang, Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu
MERL Contacts: Toshiaki Koike-Akino; Jing Liu; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
The challenge asked teams to develop autonomous robot policies for a Unitree G1 humanoid robot to assemble an IKEA UTTER table from its component parts. The robot had to perform the task autonomously at the competition venue, requiring capabilities including perception, bimanual manipulation, spatial reasoning, planning, and control. Human intervention was penalized, and teams were evaluated based on assembly progress and completion time.
MERL competed as MEL-Craft and achieved first place in the competition. The result demonstrates progress toward reliable humanoid robots capable of performing complex, contact-rich manipulation tasks in real-world environments, an important direction for physical AI and general-purpose robotic systems.
The MERL team members were Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu.
The Humanoid IKEA Assembly Challenge was held as part of IROS 2026, the IEEE/RSJ International Conference on Intelligent Robots and Systems.
- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
-
AWARD MERL Team Wins Real-TSE Challenge Track 2 on Offline Target Speaker Extraction Date: July 6, 2026
Awarded to: Dominik Klement, Yoshiki Masuyama, Christoph Boeddeker, Kohei Saijo, Julius Richter, Gordon Wichern, and Jonathan Le Roux
MERL Contacts: Christoph Boeddeker; Jonathan Le Roux; Yoshiki Masuyama; Julius Richter; Gordon Wichern
Research Areas: Artificial Intelligence, Machine Learning, Speech & AudioBriefMERL's Speech & Audio team, led by MERL intern Dominik Klement, ranked 1st out of 11 teams in Track 2, "Offline Target Speaker Extraction," of the Real-TSE Challenge. The challenge focuses on target speaker extraction (TSE) from real-world conversational recordings in either English or Chinese, where the goal is to extract the speech of a target speaker in the presence of interfering speakers, background noise, and reverberation.
While modern TSE systems have achieved strong performance on simulated speech mixtures, their performance can degrade considerably on real-world recordings due to the mismatch between simulated training data and actual conversational environments. The Real-TSE Challenge was designed to advance TSE under these realistic conditions, using real far-field conversational recordings for evaluation.
The MERL team won Track 2 by focusing on training data and curriculum learning rather than introducing a new model architecture. Starting from a strong speech separation model, the team progressively trained the system on fully overlapping synthetic speech, simulated conversations, realistic far-field mixtures, and finally real conversational recordings. This approach reduced the token error rate (TER), measured at either the word (English) or character (Chinese) level, from 70% to 37% on the development set and achieved a final TER of 61.3% on the evaluation set, best among the 11 participating teams. The team also topped the leaderboard in terms of the aggregate ranking across the four measures evaluating intelligibility, target speaker presence rate, speaker similarity, and perceptual quality.
The team also investigated the reliability of the challenge metrics and demonstrated that neural network-based speaker similarity and predicted speech-quality scores could be substantially improved without a corresponding improvement in perceptual quality. Because learned metrics can be susceptible to adversarial attacks or optimization that exploits weaknesses in the metric itself, these findings highlight both the importance of realistic training data for real-world TSE and the need for robust evaluation metrics when developing speech extraction systems.
A paper summarizing the team's findings will be presented at the IEEE Spoken Language Technology (SLT) 2026 workshop, to be held in Palermo, Italy from December 13-16, 2026.
REAL-TSE Challenge: Track 2 rankings — Offline Target Speaker Extraction Rank Team TER ↓ F1 ↑ SIM ↑ P808 ↑ Score ↓ 1 MERL 0.613 (1) 0.861 (2) 0.538 (3) 3.371 (2) 2.00 2 YiJiaHe 0.639 (2) 0.871 (1) 0.565 (1) 3.128 (9) 3.25 3 CARTSE 0.651 (3) 0.857 (4) 0.544 (2) 3.138 (8) 4.25 4 WasedaM 0.675 (5) 0.858 (3) 0.480 (6) 3.232 (6) 5.00 5 SonicAGI 0.680 (6) 0.851 (6) 0.471 (7) 3.258 (5) 6.00 6 WAKA 0.670 (4) 0.847 (8) 0.471 (7) 3.150 (7) 6.50 6 SHNU-TSE 0.731 (9) 0.840 (9) 0.507 (5) 3.362 (3) 6.50 7 ChuEst 0.710 (7) 0.831 (11) 0.532 (4) 3.064 (10) 8.00 8 pyannoteAI 0.728 (8) 0.855 (5) 0.464 (9) 2.904 (12) 8.50 9 AGH-JHU 0.743 (10) 0.837 (10) 0.434 (11) 3.335 (4) 8.75 10 WHU_IASP 0.757 (11) 0.850 (7) 0.465 (8) 2.961 (11) 9.25 11 CUDA_OUT_OF_MEMORY 0.827 (12) 0.819 (13) 0.364 (13) 3.435 (1) 9.75 12 BSRNN_EMB Baseline 0.829 (13) 0.829 (12) 0.417 (12) 2.875 (13) 12.50 12 BSRNN_TFMAP Baseline 0.838 (14) 0.829 (12) 0.443 (10) 2.756 (14) 12.50 ↓ Lower is better; ↑ higher is better. Parentheses show metric ranks. The score is the average of the four dense metric ranks; tied scores share a position. Best metric values are bold. P808 denotes DNSMOS-P808.
Source: Official REAL-TSE Challenge rankings. BSRNN entries are organizer baselines.
-
AWARD MERL Team Wins DCASE 2026 Challenge on Anomalous Sound Detection for Machine Condition Monitoring Date: June 30, 2026
Awarded to: Takuya Fujimura, Gordon Wichern, Yoshiki Masuyama, Christoph Boeddeker, Kohei Saijo, Julius Richter, Takahiro Edo, and Jonathan Le Roux
MERL Contacts: Christoph Boeddeker; Jonathan Le Roux; Yoshiki Masuyama; Julius Richter; Gordon Wichern
Research Areas: Artificial Intelligence, Machine Learning, Signal Processing, Speech & AudioBrief- MERL's Speech & Audio team ranked 1st out of 51 teams in the DCASE 2026 Challenge’s Task 2, “Noise-aware Unsupervised Anomalous Sound Detection for Machine Condition Monitoring.” The team was led by MERL intern Takuya Fujimura, and also included Gordon Wichern, Yoshiki Masuyama, Christoph Boeddeker, Kohei Saijo, Julius Richter, Takahiro Edo, and Jonathan Le Roux.
The IEEE AASP Challenge on Detection and Classification of Acoustic Scenes and Events (DCASE Challenge), started in 2013, has been organized yearly since 2016, and gathers challenges on multiple tasks related to the detection, analysis, and generation of sound events. This year, the DCASE 2026 Challenge received 421 submissions from 135 teams across seven tasks.
The MERL team won Task 2, Noise-aware Unsupervised Anomalous Sound Detection for Machine Condition Monitoring, which aims at building noise-robust systems for automatically detecting machine failure via microphones when only normal machine operating data is available for system development. Task 2 was by far the most popular out of the 7 DCASE 2026 tasks, with 51 teams submitting 168 entries. The MERL team's system was built around MERL’s recently proposed paradigm of noise-aware self-supervised learning, which extracts noise robust features leveraging two-channel recordings, in which one microphone is used to capture noise. Anomaly detection is then performed in the extracted denoised feature space using advanced score normalization. The team's best submission obtained a composite score of 70.24% on five evaluation machines, largely outperforming the 2nd best team's 65.45%.
MERL also participated in Task 4, Spatial Semantic Segmentation of Sound Scenes (S5) and placed 3rd out of 10 teams in separation performance. Our cascaded system consists of universal sound separation with source counting, source classification, and class-aware refinement, where the separation and refinement modules are built upon MERL's TF-Locoformer separation technology. Notably, the team's best submission obtained a label prediction accuracy of 76.92% on the evaluation set, largely outperforming the 2nd best team's 65.54%.
- MERL's Speech & Audio team ranked 1st out of 51 teams in the DCASE 2026 Challenge’s Task 2, “Noise-aware Unsupervised Anomalous Sound Detection for Machine Condition Monitoring.” The team was led by MERL intern Takuya Fujimura, and also included Gordon Wichern, Yoshiki Masuyama, Christoph Boeddeker, Kohei Saijo, Julius Richter, Takahiro Edo, and Jonathan Le Roux.
See All Awards for Machine Learning -
-
News & Events
-
NEWS MERL contributes to IROS 2026 Date: September 27, 2026 - October 1, 2026
Where: The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
MERL Contacts: Siddarth Jain; Toshiaki Koike-Akino; Jing Liu; Daniel N. Nikovski; Arvind Raghunathan; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
Main Conference Paper
- ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation, Yunfu Deng and Daniel N. Nikovski (TR2026-141)
The work introduces a geometric representation for articulated-object manipulation, enabling robots to infer compact representations of previously unknown articulated mechanisms for downstream learning and control.
Workshop Papers
- Deliberate Practice: Learning Robot Skills under a Budget Shivam Vats, Sudarshan Harithas, Mete Akbulut, Arvind Raghunathan, and George Konidaris (TR2026-147)
- ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies, Haodi Hu, Chung-Ta Huang, Jing Liu, Ye Wang, Kei Suzuki, Matthew Brand, and Toshiaki Koike-Akino (TR2026-148)
- Test-Time Attention: Can Robots Better Follow Commands? Jing Liu, Ye Wang, Kei Suzuki, and Toshiaki Koike-Akino (TR2026-142)
- Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation, Chak Lam Shek, Ye Wang, Jing Liu, Kei Suzuki, Pratap Tokekar, and Toshiaki Koike-Akino (TR2026-149)
- DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments, Harsh Singh, Kei Suzuki, Ye Wang, Jing Liu, Paola Cascante-Bonilla, and Toshiaki Koike-Akino (TR2026-146)
Together, these works address a range of challenges in modern robotics, including articulated-object manipulation, efficient robot skill learning, vision-language-action policies, test-time adaptation, autonomous factory operation, and dynamic manipulation. The paper on ReCoVLA was nominated as a spotlight talk.
Robotics Community Contributions
MERL Principal Research Scientist Dr. Siddarth Jain participated in the IEEE Robotics and Automation Letters (RA-L) editorial board meeting at IROS. Dr. Jain serves as an Associate Editor of RA-L, contributing to the peer-review and editorial activities of the robotics research community.
Former MERL scientist Dr. Diego Romeres was also among the organizers of the 1st International Workshop on Industrial Applications of Robot Learning (IARL 2026). The workshop brought together researchers from academia and industry to discuss how advances in robot learning can be translated into reliable and scalable real-world industrial robotic systems.
Humanoid IKEA Assembly Challenge
MERL also participated in the IROS 2026 Humanoid IKEA Assembly Challenge with Team MEL-Craft. The team achieved first place in the competition, demonstrating autonomous humanoid manipulation capabilities for a challenging furniture-assembly task. The MEL-Craft team included MERL researchers Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Haodi Hu, Harsh Singh, Chak Lam Shek, and Maxwell Asselmeier. The competition achievement is highlighted separately in MERL's related award announcement.
About IROS
The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) is a major international robotics conference bringing together researchers, engineers, and industry practitioners working across intelligent robots and systems. IROS 2026 took place in Pittsburgh from September 27 to October 1, 2026.
- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
-
TALK [MERL Seminar Series 2026] Yuanqi Du presents talk titled Towards Generalist Agents for Accelerating Scientific Discovery Date & Time: Wednesday, September 16, 2026; 12:00 PM
Speaker: Yuanqi Du, Microsoft Research New England
MERL Host: Pu (Perry) Wang
Research Areas: Artificial Intelligence, Machine LearningAbstract Large language models (LLMs) are opening new frontiers in scientific research, enabling capabilities ranging from literature retrieval and hypothesis generation to experimental planning and operation, and bringing us closer to the vision of an AI Scientist. However, it remains unclear what principles should guide the development of such an AI Scientist. In this talk, I will ground this vision in the scientific discovery workflow that drives human progress. First, I will present quantitative evidence of how LLMs are changing the way we search for and validate hypotheses, and how they can serve as powerful tools for hypothesis search. Next, I will discuss how automation can enter the loop by steering the decision-making process. Finally, I will discuss the path toward truly autonomous agents that can operate without any human intervention. These generalist agents are being validated across problems in chemistry, biology, and materials science, including through wet-lab experiments.
See All News & Events for Machine Learning -
-
Research Highlights
-
ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies -
LLawCo: Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior -
Point4Cast: Streaming Dynamic Scene Reconstruction and Forecasting -
AssemblyBench: Physics-Aware Assembly of Complex Industrial Objects -
SLAM-MER: Revisiting Monocular SLAM with Spatio-Temporal Scene Modeling -
Parallel Rigidity Matters for Bundle Adjustment -
LLMPhy: Parameter-Identifiable Physical Reasoning Combining Large Language Models and Physics Engines -
BodyVLA: Embedding Morphology into Transformers for Cross-Robot Policy Learning -
SAC-GNC: SAmple Consensus for adaptive Graduated Non-Convexity -
PS-NeuS: A Probability-guided Sampler for Neural Implicit Surface Rendering -
Quantum AI Technology -
TI2V-Zero: Zero-Shot Image Conditioning for Text-to-Video Diffusion Models -
Gear-NeRF: Free-Viewpoint Rendering and Tracking with Motion-Aware Spatio-Temporal Sampling -
Private, Secure, and Reliable Artificial Intelligence -
Steered Diffusion -
Sustainable AI -
Edge-Assisted Internet of Vehicles for Smart Mobility -
Robust Machine Learning -
mmWave Beam-SNR Fingerprinting (mmBSF) -
Video Anomaly Detection -
Biosignal Processing for Human-Machine Interaction -
MERL Shopping Dataset -
Task-aware Unified Source Separation - Audio Examples
-
-
Internships
-
ST0238: Internship - Multi-Modal Sensing and Understanding
-
EA0237: Internship - Condition Monitoring and Fault Diagnosis
-
CV0101: Internship - Multimodal Algorithmic Reasoning
See All Internships for Machine Learning -
-
Openings
-
MS0268: Research Scientist - Plasma Modeling and Control
-
CI0177: Postdoctoral Research Fellow - Agentic AI
See All Openings at MERL -
-
Recent Publications
- , "Demagnetization Fault Detection in PMSMs with Online Inductance Estimation", IEEE Energy Conversion Congress and Exposition (ECCE), October 2026.BibTeX TR2026-152 PDF
- @inproceedings{Yang2026oct,
- author = {Yang, Ge and Wang, Yebin and Goldsmith, Abraham and Lin, Chungwei and Wang, Bingnan},
- title = {{Demagnetization Fault Detection in PMSMs with Online Inductance Estimation}},
- booktitle = {IEEE Energy Conversion Congress and Exposition (ECCE)},
- year = 2026,
- month = oct,
- url = {https://www.merl.com/publications/TR2026-152}
- }
- , "Echoes after Edits: Room Impulse Response Estimation for Geometry Update", Interspeech, DOI: 10.21437/Interspeech.2026-2514, September 2026, pp. 2958-2962.BibTeX TR2026-140 PDF
- @inproceedings{Bhosale2026sep2,
- author = {Bhosale, Swapnil and Masuyama, Yoshiki and Chatterjee, Moitreya and Boeddeker, Christoph and Richter, Julius and Wichern, Gordon and {Le Roux}, Jonathan},
- title = {{Echoes after Edits: Room Impulse Response Estimation for Geometry Update}},
- booktitle = {Interspeech},
- year = 2026,
- pages = {2958--2962},
- month = sep,
- doi = {10.21437/Interspeech.2026-2514},
- issn = {2958-1796},
- url = {https://www.merl.com/publications/TR2026-140}
- }
- , "Dual-Geometry Manifolds for Few-shot RIR Prediction", Interspeech, September 2026, pp. 2963-2967.BibTeX TR2026-139 PDF Software
- @inproceedings{Bhosale2026sep,
- author = {Bhosale, Swapnil and Wichern, Gordon and Masuyama, Yoshiki and Chatterjee, Moitreya and Boeddeker, Christoph and Richter, Julius and Zhu, Xiatian and {Le Roux}, Jonathan},
- title = {{Dual-Geometry Manifolds for Few-shot RIR Prediction}},
- booktitle = {Interspeech},
- year = 2026,
- pages = {2963--2967},
- month = sep,
- issn = {2958-1796},
- url = {https://www.merl.com/publications/TR2026-139}
- }
- , "Speaker Identity as Sole Supervision for Speech Separation", Interspeech, September 2026.BibTeX TR2026-137 PDF
- @inproceedings{Boeddeker2026sep,
- author = {Boeddeker, Christoph and Masuyama, Yoshiki and Richter, Julius and Edo, Takahiro and Wichern, Gordon and {Le Roux}, Jonathan},
- title = {{Speaker Identity as Sole Supervision for Speech Separation}},
- booktitle = {Interspeech},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-137}
- }
- , "Plan and Double-Check: Streaming Multimodal Q-Former for Online Robot Action Generation", Interspeech, September 2026.BibTeX TR2026-136 PDF
- @inproceedings{Hori2026sep,
- author = {{Hori, Chiori and Korekata, Ryosuke and Kambara, Motonari and Masuyama, Yoshiki and Jain, Siddarth and Corcodel, Radu and Romeres, Diego and Le Roux, Jonathan}},
- title = {{Plan and Double-Check: Streaming Multimodal Q-Former for Online Robot Action Generation}},
- booktitle = {Interspeech},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-136}
- }
- , "ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.BibTeX TR2026-148 PDF
- @inproceedings{Hu2026sep,
- author = {Hu, Haodi and Huang, Chung-Ta and Liu, Jing and Wang, Ye and Suzuki, Kei and Brand, Matthew and Koike-Akino, Toshiaki},
- title = {{ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-148}
- }
- , "Test-Time Attention: Can Robots Better Follow Commands?", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) IARL Workshop, September 2026.BibTeX TR2026-142 PDF
- @inproceedings{Liu2026sep,
- author = {Liu, Jing and Wang, Ye and Suzuki, Kei and Koike-Akino, Toshiaki},
- title = {{Test-Time Attention: Can Robots Better Follow Commands?}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) IARL Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-142}
- }
- , "HRTF Personalization via Sim-to-Real Neural Field", Interspeech, DOI: 10.21437/Interspeech.2026-1391, September 2026, pp. 696-701.BibTeX TR2026-135 PDF Software
- @inproceedings{Masuyama2026sep2,
- author = {Masuyama, Yoshiki and Wichern, Gordon and Boeddeker, Christoph and Richter, Julius and Edo, Takahiro and Bhosale, Swapnil and {Le Roux}, Jonathan},
- title = {{HRTF Personalization via Sim-to-Real Neural Field}},
- booktitle = {Interspeech},
- year = 2026,
- pages = {696--701},
- month = sep,
- doi = {10.21437/Interspeech.2026-1391},
- issn = {2958-1796},
- url = {https://www.merl.com/publications/TR2026-135}
- }
- , "Demagnetization Fault Detection in PMSMs with Online Inductance Estimation", IEEE Energy Conversion Congress and Exposition (ECCE), October 2026.
-
Videos
-
Software & Data Downloads
-
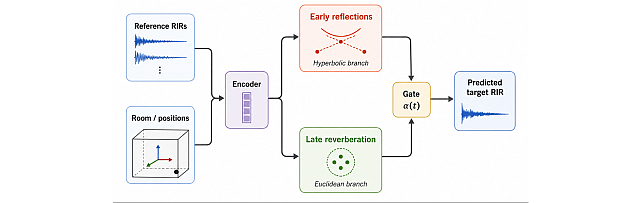
Dual-Geometry Manifolds for Few-shot RIR Prediction -
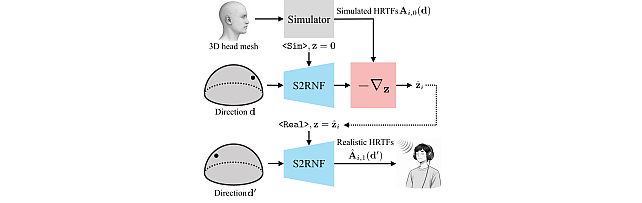
Sim-to-Real Neural Field -
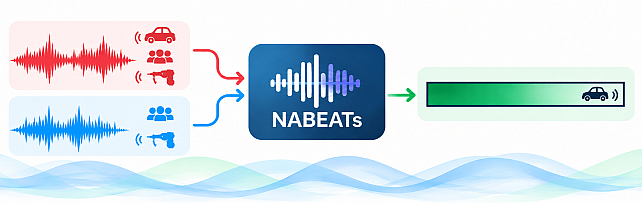
Noise-Aware Audio Representation Learning -
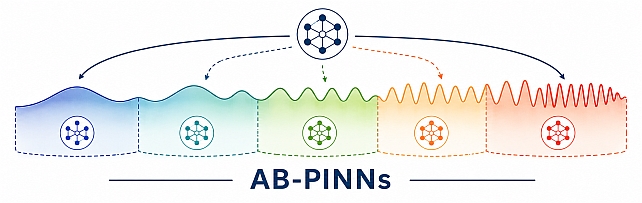
Adaptive-Basis Physics-Informed Neural Networks for Residual-Driven Domain Decomposition -
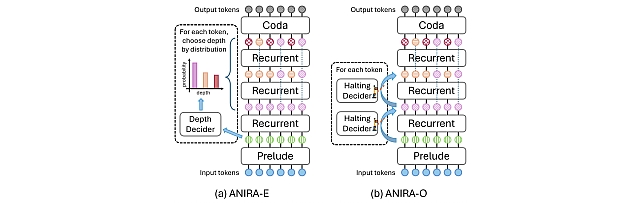
Understanding Dynamic Compute Allocation in Recurrent Transformers -
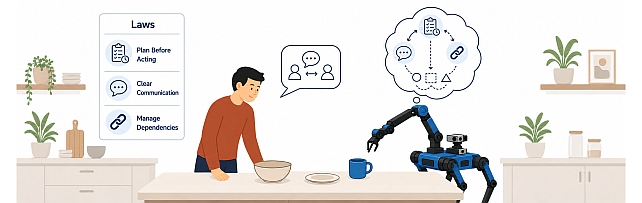
Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior -
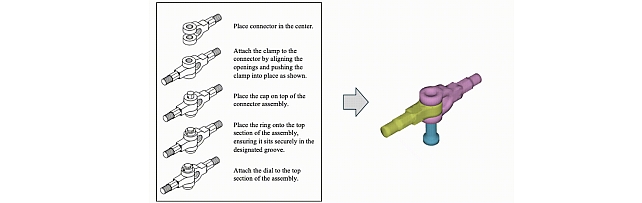
Physics-Aware Assembly of Complex Industrial Objects -
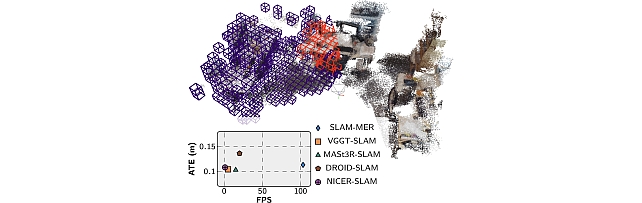
Mitsubishi Electric Research framework for visual SLAM -
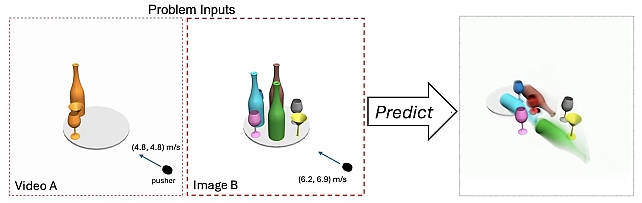
Parameter-Identifiable Physical Reasoning Combining Large Language Models and Physics Engines -
Directional Embedding Smoothing for Robust Vision Language Models -
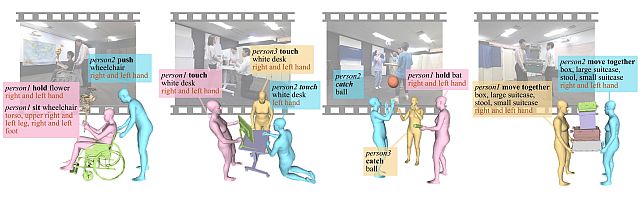
MMHOI Dataset: Modeling Complex 3D Multi-Human Multi-Object Interactions -
Embracing Cacophony -
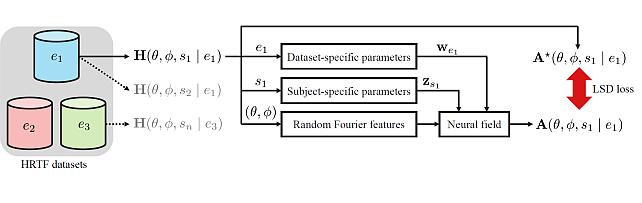
Subject- and Dataset-Aware Neural Field for HRTF Modeling -
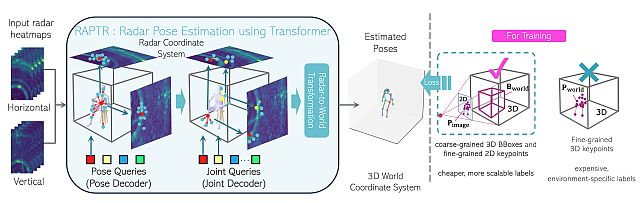
Radar-based 3D Pose Estimation using Transformer -
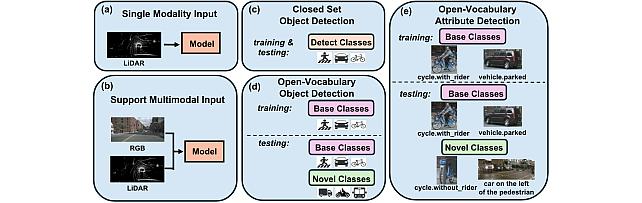
Open Vocabulary Attribute Detection Dataset -
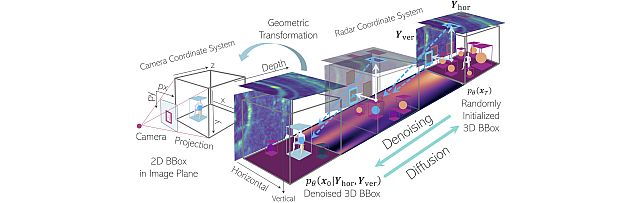
multi-view Radar object dEtection with 3D bounding boX diffusiOn -
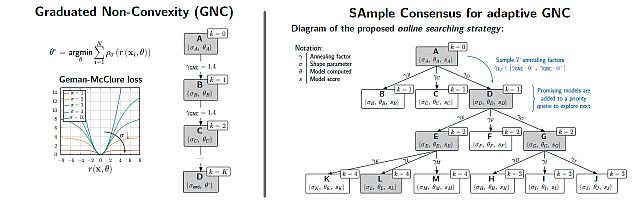
SAmple Consensus for Adaptive Graduated Non-Convexity -
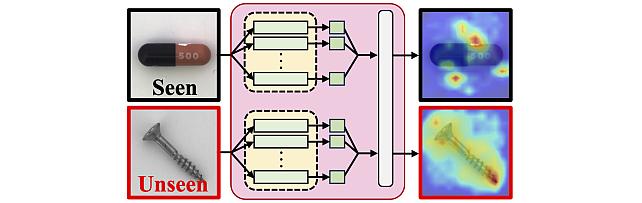
Long-Tailed Online Anomaly Detection dataset -
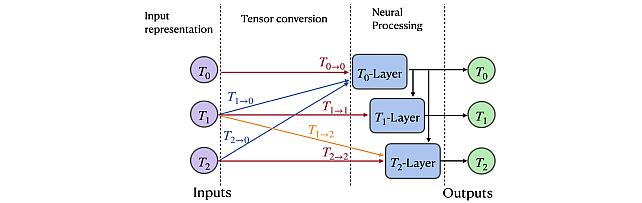
Group Representation Networks -
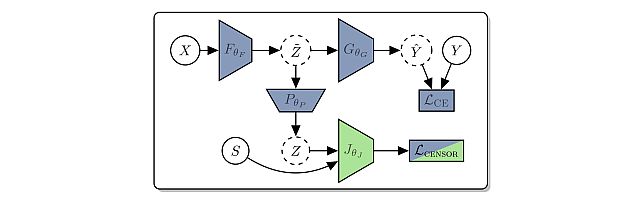
Stabilizing Subject Transfer in EEG Classification with Divergence Estimation -
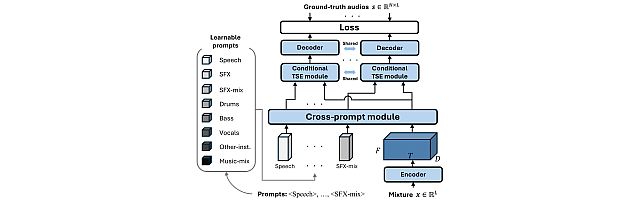
Task-Aware Unified Source Separation -
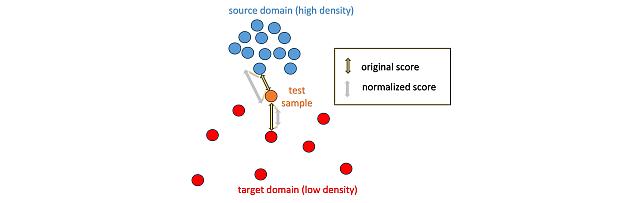
Local Density-Based Anomaly Score Normalization for Domain Generalization -
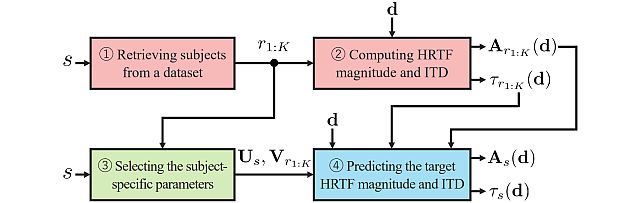
Retrieval-Augmented Neural Field for HRTF Upsampling and Personalization -
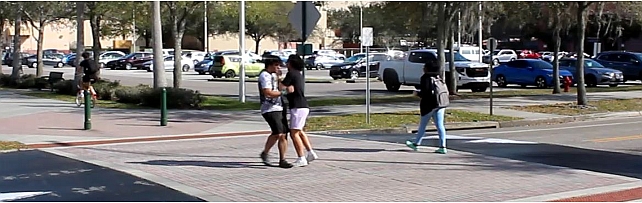
ComplexVAD Dataset -
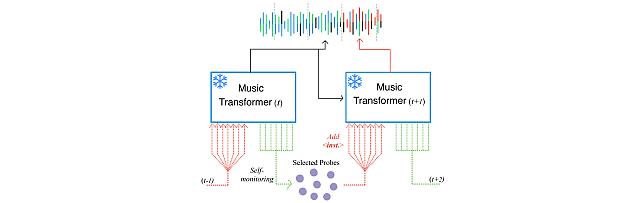
Self-Monitored Inference-Time INtervention for Generative Music Transformers -
MEL-PETs Defense for LLM Privacy Challenge -
MEL-PETs Joint-Context Attack for LLM Privacy Challenge -
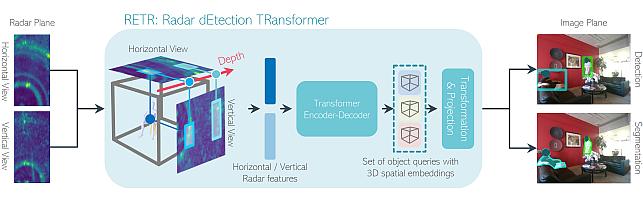
Radar dEtection TRansformer -
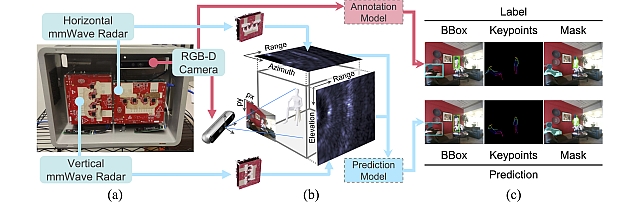
Millimeter-wave Multi-View Radar Dataset -
Zero-Shot Image Conditioning for Text-to-Video Diffusion Models -
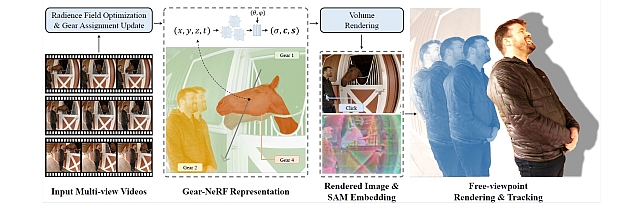
Gear Extensions of Neural Radiance Fields -
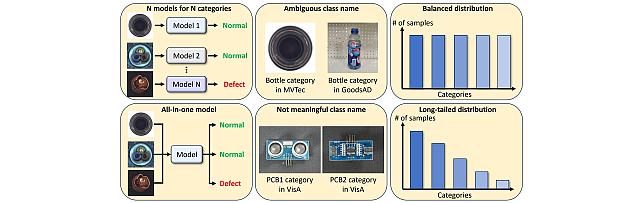
Long-Tailed Anomaly Detection Dataset -
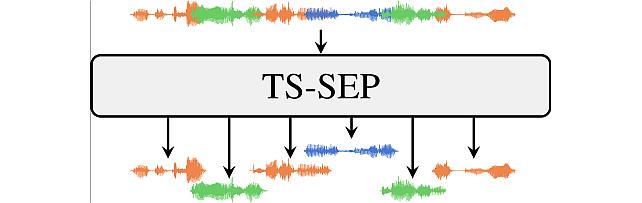
Target-Speaker SEParation -
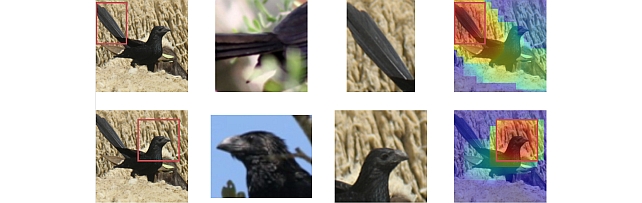
Pixel-Grounded Prototypical Part Networks -
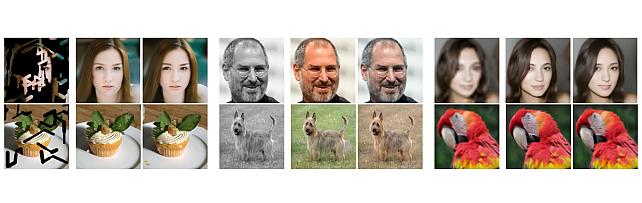
Steered Diffusion -
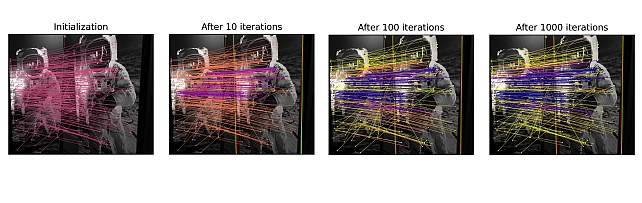
BAyesian Network for adaptive SAmple Consensus -
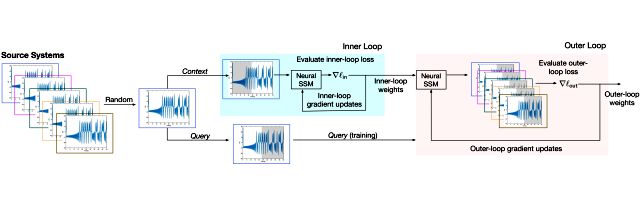
Meta-Learning State Space Models -
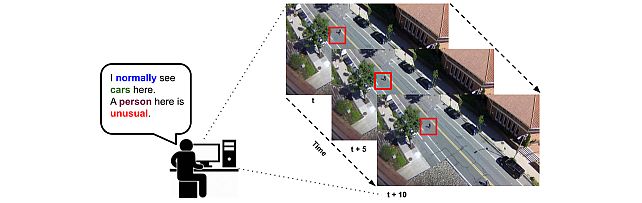
Explainable Video Anomaly Localization -
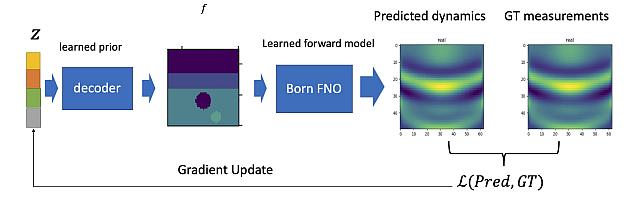
Learned Born Operator for Reflection Tomographic Imaging -
Simple Multimodal Algorithmic Reasoning Task Dataset -
Partial Group Convolutional Neural Networks -
SOurce-free Cross-modal KnowledgE Transfer -
Audio-Visual-Language Embodied Navigation in 3D Environments -
Nonparametric Score Estimators -
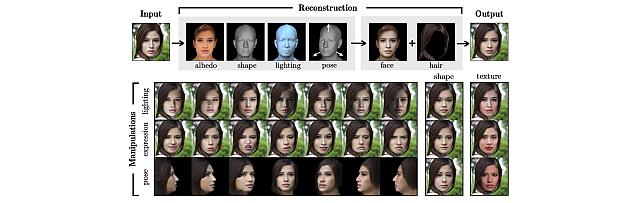
3D MOrphable STyleGAN -
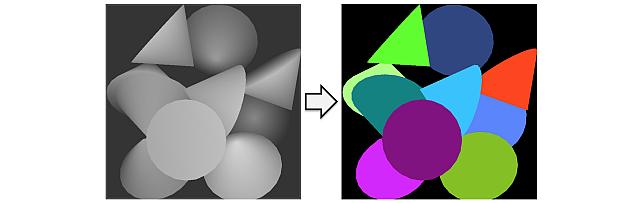
Instance Segmentation GAN -
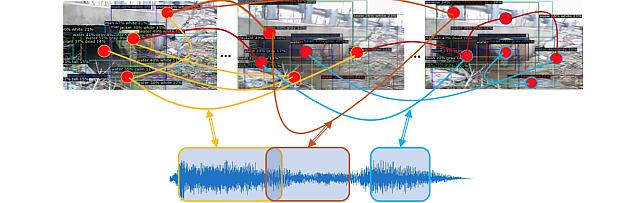
Audio Visual Scene-Graph Segmentor -
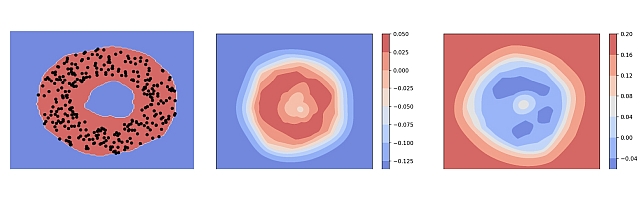
Generalized One-class Discriminative Subspaces -
Hierarchical Musical Instrument Separation -
Generating Visual Dynamics from Sound and Context -
Adversarially-Contrastive Optimal Transport -
Online Feature Extractor Network -
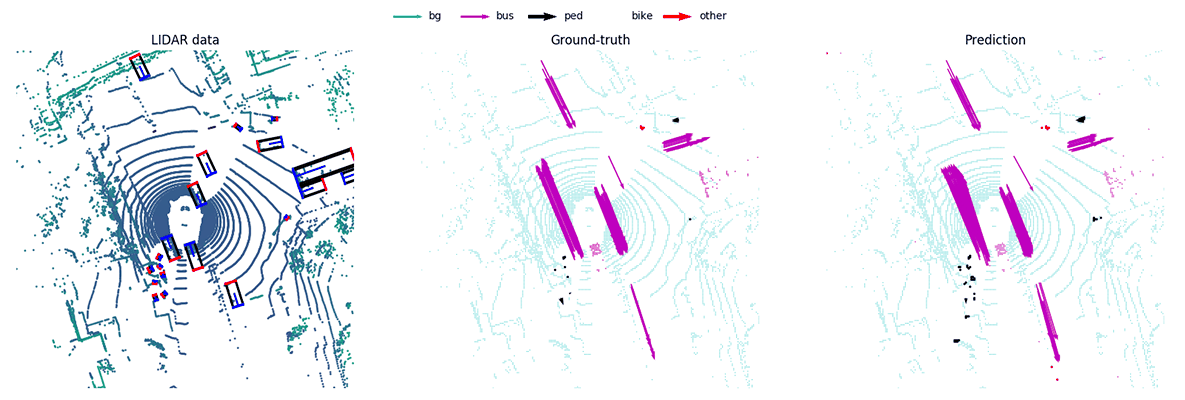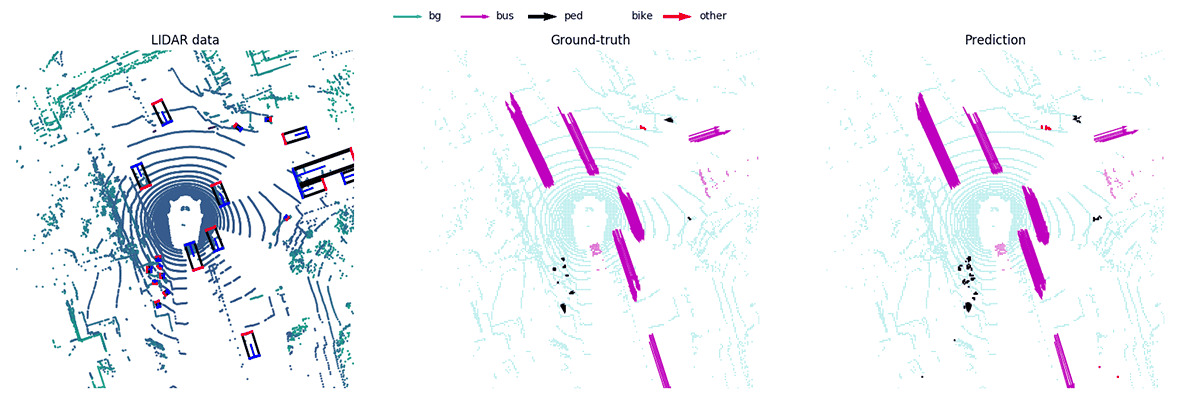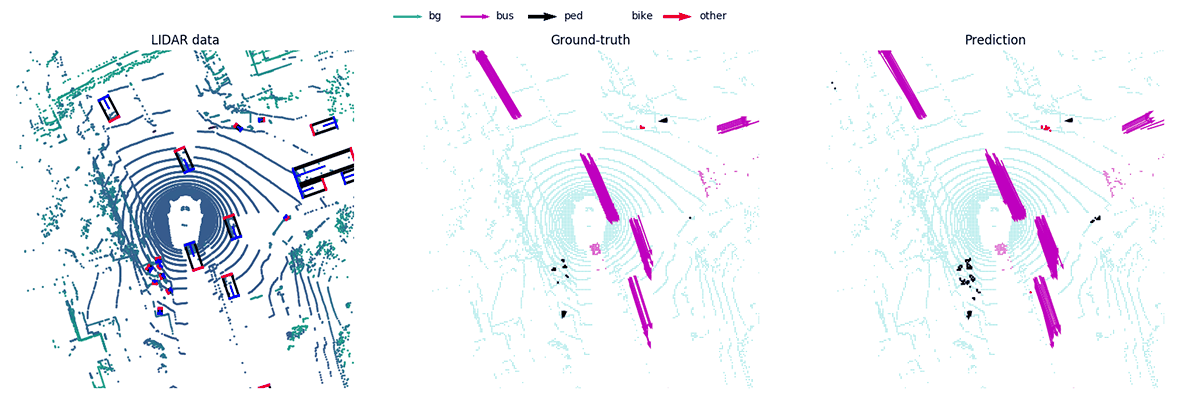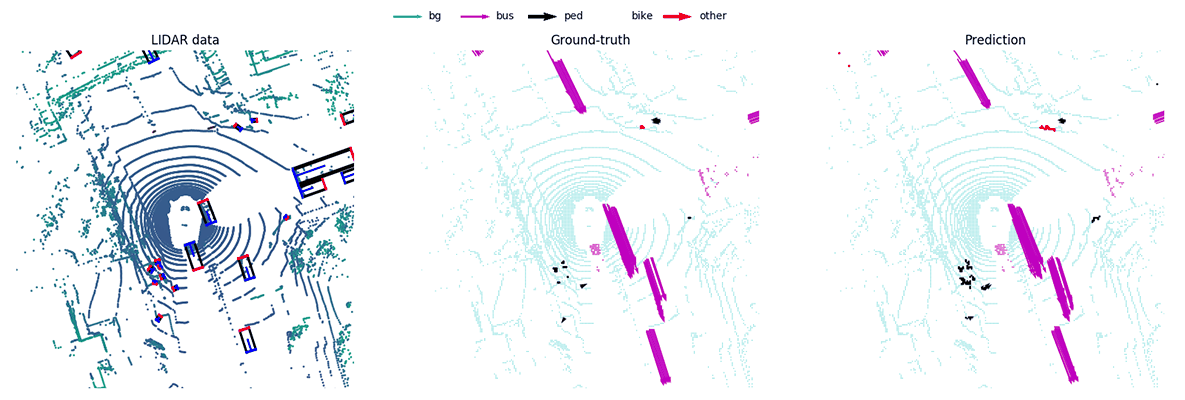
MotionNet -
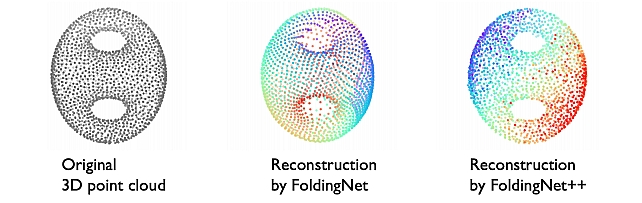
FoldingNet++ -
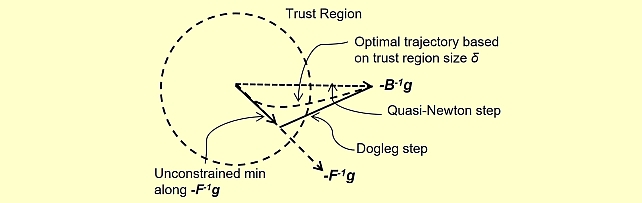
Quasi-Newton Trust Region Policy Optimization -
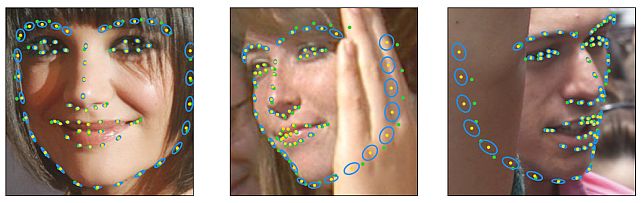
Landmarks’ Location, Uncertainty, and Visibility Likelihood -
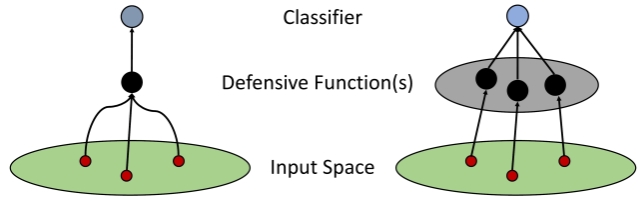
Robust Iterative Data Estimation -
Gradient-based Nikaido-Isoda -
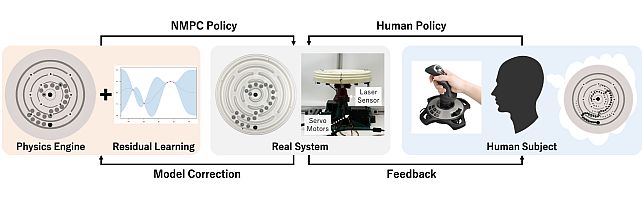
Circular Maze Environment -
Discriminative Subspace Pooling -
Kernel Correlation Network -
Fast Resampling on Point Clouds via Graphs -
FoldingNet -
Deep Category-Aware Semantic Edge Detection -
MERL Shopping Dataset -
Generalization in Deep RL with a Robust Adaptation Module -
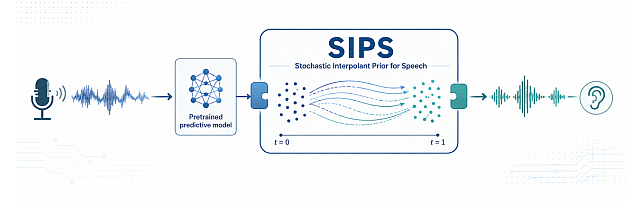
Stochastic Interpolants for Speech Enhancement and Separation
-